Benchmarks
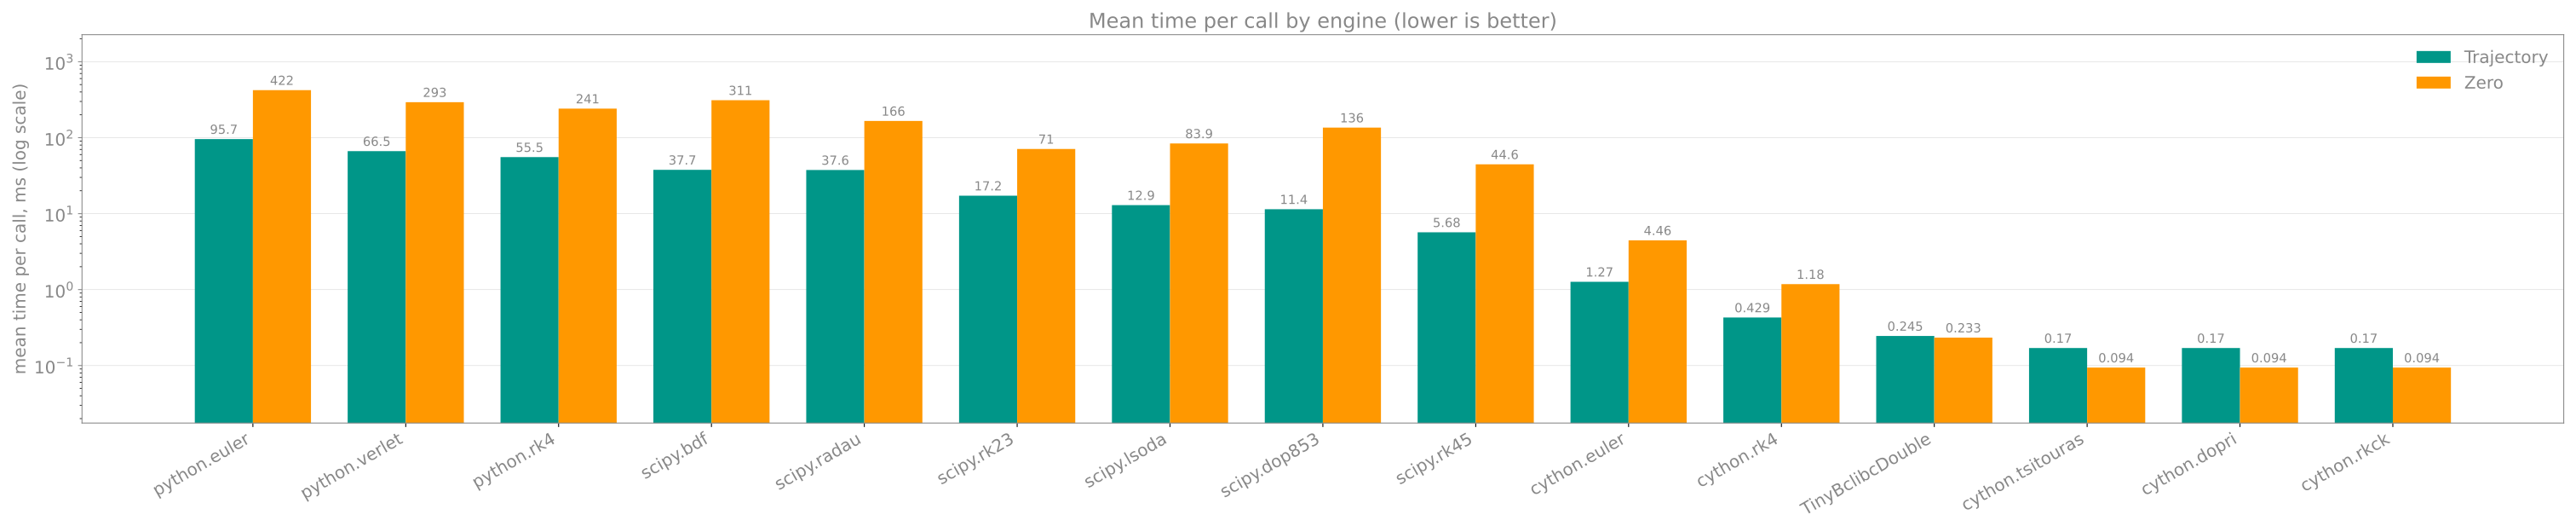
Mean time per call for each engine (lower is better), generated from
benchmarks/benchmarks.csv by scripts/bench_report.py.
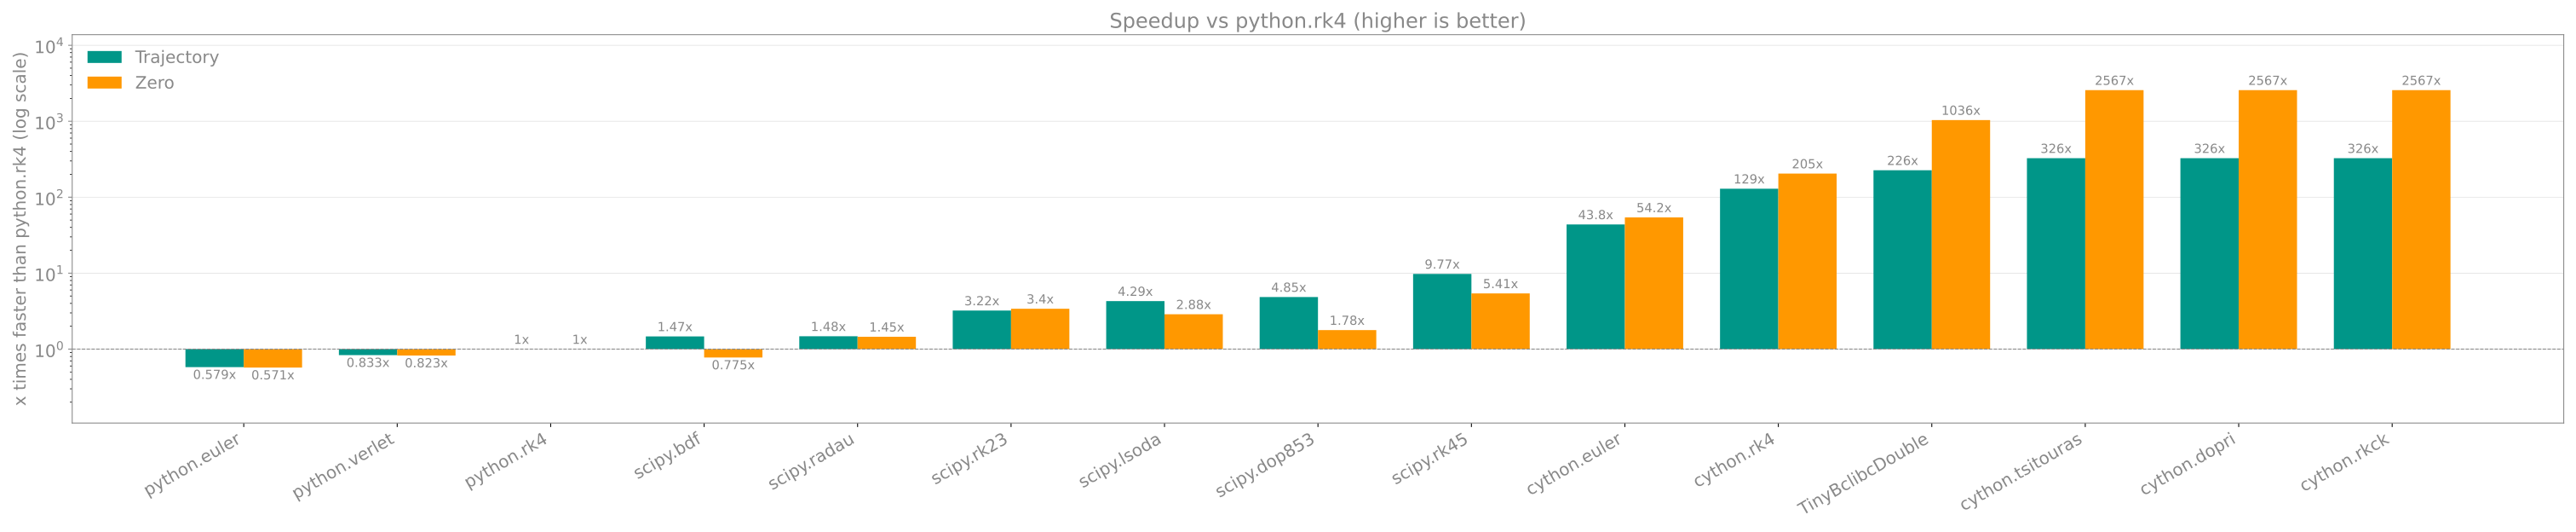
Each engine has two bars: Trajectory (fire a trajectory) and Zero (find the zero angle).
The vertical scales are logarithmic.
Mean time
Speedup vs python.rk4
- Version:
3.0.0b3.dev7+ga8145b128.d20260921(branchnew-entry-points, commitef170c8) - Where an engine was run several times, the run with the most repeats is used.
- Only engines present in the benchmark data are listed.
Results
| Engine | Trajectory, ms | vs python.rk4 |
Zero, ms | vs python.rk4 |
Repeats |
|---|---|---|---|---|---|
python.euler |
95.744 | 0.579x | 422.462 | 0.571x | 50 |
python.verlet |
66.536 | 0.833x | 293.166 | 0.823x | 50 |
python.rk4 |
55.455 | 1x | 241.340 | 1x | 50 |
scipy.bdf |
37.744 | 1.47x | 311.273 | 0.775x | 100 |
scipy.radau |
37.555 | 1.48x | 166.027 | 1.45x | 500 |
scipy.rk23 |
17.228 | 3.22x | 71.026 | 3.4x | 500 |
scipy.lsoda |
12.939 | 4.29x | 83.901 | 2.88x | 500 |
scipy.dop853 |
11.439 | 4.85x | 135.603 | 1.78x | 100 |
scipy.rk45 |
5.678 | 9.77x | 44.611 | 5.41x | 500 |
cython.euler |
1.267 | 43.8x | 4.455 | 54.2x | 500 |
cython.rk4 |
0.429 | 129x | 1.179 | 205x | 1000 |
tiny_bclibc_ctypes:TinyBclibcDoubleIntegrationEngine |
0.245 | 226x | 0.233 | 1036x | 500 |
cython.tsitouras |
0.170 | 326x | 0.094 | 2567x | 2000 |
cython.dopri |
0.170 | 326x | 0.094 | 2567x | 2000 |
cython.rkck |
0.170 | 326x | 0.094 | 2567x | 2000 |
Note
Adaptive engines (cython.rkck, cython.dopri, cython.tsitouras) take far fewer steps than
fixed-step RK4, which is why Zero shows such a large gap. Results depend on hardware and workload;
treat them as relative figures. See Engines for the engine overview.